LIBRISTO
LIBROAMANTO
obvezno
Postanite del skupnosti ljubiteljev knjig z vsega sveta in uživajte v številnih ugodnostih. Ustvarite brezplačen račun
0
Brezplačna dostava Zásilkovna nad 69.99 €
Zbirna točka GLS 4.49 Zbirna točka DPD 2.99 Kurirska služba GLS 5.49 Kurir DPD 3.49 Kurirska služba Express One 3.49 Zbirno mesto Express One 3.49 Zbirno mesto Pošte Slovenije 3.49 Dostava preko Pošte Slovenije 3.49

Brezplačna dostava za naročila nad 69,99 € na prevzemna mesta DPD in Express One.

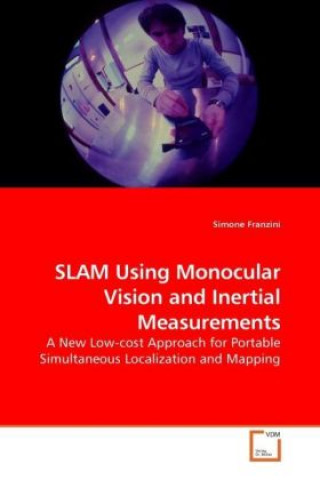
SLAM Using Monocular Vision and Inertial Measurements

A New Low-cost Approach for Portable Simultaneous Localization and Mapping

Jezik AngleščinaAngleščina
Knjiga Mehka
Knjiga SLAM Using Monocular Vision and Inertial Measurements Simone Franzini
Koda Libristo: 06818887
Založba VDM Verlag Dr. Müller, november 2008
Simultaneous Localization and Mapping, comprising estimation of robot ego-motion and building a map... Celoten opis
? points 108 b
44.23
Od založnika po naročilu Odposlali bomo v 17-27 dneh

Do 30 dni za vračilo


Drugi so kupili tudi


Simultaneous Localization and Mapping, comprising estimation of robot ego-motion and building a map of the surrounding environment, is one of the most fundamental tasks of mobile robotics. Many SLAM systems proposed in the past make use of the Global Positioning System (GPS), which renders them both expensive and overly dependent on the presence of the GPS signal. We propose an alternative, low-cost approach for portable SLAM which is based on monocular vision, a promising technique due to its flexibility, ease of use, and ease of calibration. In order to perform this task we use an Extended Kalman Filter, one of the most efficient and robust methods used in SLAM systems. We show how it is possible to improve the estimated position and reduce its uncertainty by fusing data from different sensors, in particular using a simple 3-axis accelerometer. We prove, through careful and intelligent selection and tuning of image analysis algorithms, that real-time, low-cost SLAM is feasible. This work is useful to professionals developing SLAM systems and to people in the larger field of computer vision, especially those interested in feature detection and tracking.

Igralka & Poliglotka
EWA KASP za
Predvajaj video
Ewa Kasp
Libristo ima največjo izbiro tujejezične literature. Zato svoje knjige kupujem tukaj.

O knjigi

Polni naslov SLAM Using Monocular Vision and Inertial Measurements
Jezik Angleščina
Vezava Knjiga - Mehka
Datum izida 2009
Število strani 80
EAN 9783639098655
Koda Libristo 06818887
Teža 124
Mere 150 x 220 x 5
Podarite to knjigo še danes
To je povsem preprosto
1 Dodajte knjigo v košarico in izberite dostavo kot darilo 2 V zameno vam bomo poslali kupon 3 Knjiga bo dostavljena na naslov obdarovanca

Morda bi vas zanimalo tudi


Can I Have a Hug First? Mary Paula Hunter / Knjiga Mehka
common.buy 13.97
Revised Laws of the State of California California Laws Statutes Etc / Knjiga Mehka
common.buy 35.18
Playing Dirty Tess Summers / Knjiga Mehka
common.buy 21.21
Wild Geese and Angel's Doug Harrington / Knjiga Mehka
common.buy 20.10
The Explosive Story of Fireworks! Kama Einhorn / Knjiga Trda
common.buy 14.77
Minnesota in the Campaigns of Vicksburg, November 1862-July 1863 Minnesota-Vicksburg Monument Commission / Knjiga Trda
common.buy 28.15
Secrets She Left Behind Diane Chamberlain / Knjiga Mehka
common.buy 19.30
Wireless Medical Surveillance System Michael Krause / Knjiga Mehka
common.buy 48.36
Playing the Violin Mark Rush / Knjiga Mehka
common.buy 51.27
Honourable Jane. a Novel. Annie Hall Thomas Cudlip / Knjiga Mehka
common.buy 20.70
How I Changed My Life Todd Strasser / Knjiga Mehka
common.buy 10.15

Prijava

Prijavite se v svoj račun. Še nimate računa Libristo? Ustvarite ga zdaj!

 
obvezno
obvezno

Še nimate računa? Izkoristite prednosti računa Libristo!

Z računom Libristo boste imeli vedno vse pod nadzorom.

Ustvarite račun Libristo
Knjižni svetovalec Libroamiko
Pozdravljeni, sem Libroamiko, vam lahko pomagam?