
 Kontakt
 Kako nakupovati

Dostava
Svetovalec pri nakupu
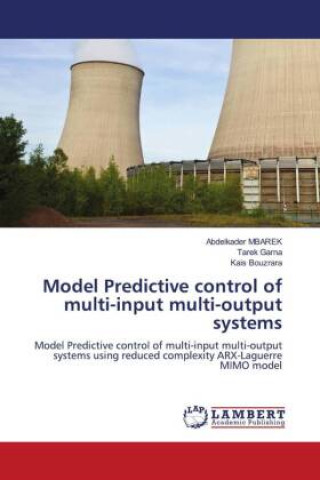
Model Predictive control of multi-input multi-output systems
Model Predictive control of multi-input multi-output systems using reduced complexity ARX-Laguerre MIMO model
 Angleščina
 81 b
Do 30 dni za vračilo
Drugi so kupili tudi


 /
 Trda
 29.10
€



 /
Mehka
2.39
€


 /
Mehka
20.90
€





 /
Mehka
34.20
€



In this work, a novel method is constructed for model predictive control (MPC) of Multi-Input Multi-Output (MIMO) systems. These latter are represented by a discrete-time MIMO ARX model expansion on Laguerre orthonormal bases. The resulting model entitled MIMO ARX-Laguerre model, provides a recursive representation with parameter number reduction. The recursive formulation of the MIMO ARX-Laguerre model is used to obtain the MPC strategy and to synthesizing an adaptive predictive controller of MIMO systems. The adaptive predictive control law is computed based on multi-step-ahead finite-element predictors, identified directly from experimental input/output data. The model is tuned in each iteration by an online identification algorithm of both model parameters and Laguerre poles.


O knjigi
Angleščina

Podarite to knjigo še danes
To je povsem preprosto
1 Dodajte knjigo v košarico in izberite dostavo kot darilo 2 V zameno vam bomo poslali kupon 3 Knjiga bo dostavljena na naslov obdarovancaMorda bi vas zanimalo tudi


 /
Mehka
27.10
€


 /
 Adobe ePub DRM
138.25
€
 /
Adobe ePub DRM
114.24
€

Pozdravljeni! Sem Libroamiko, vaš knjižni svetovalec.
Kako vam lahko pomagam?